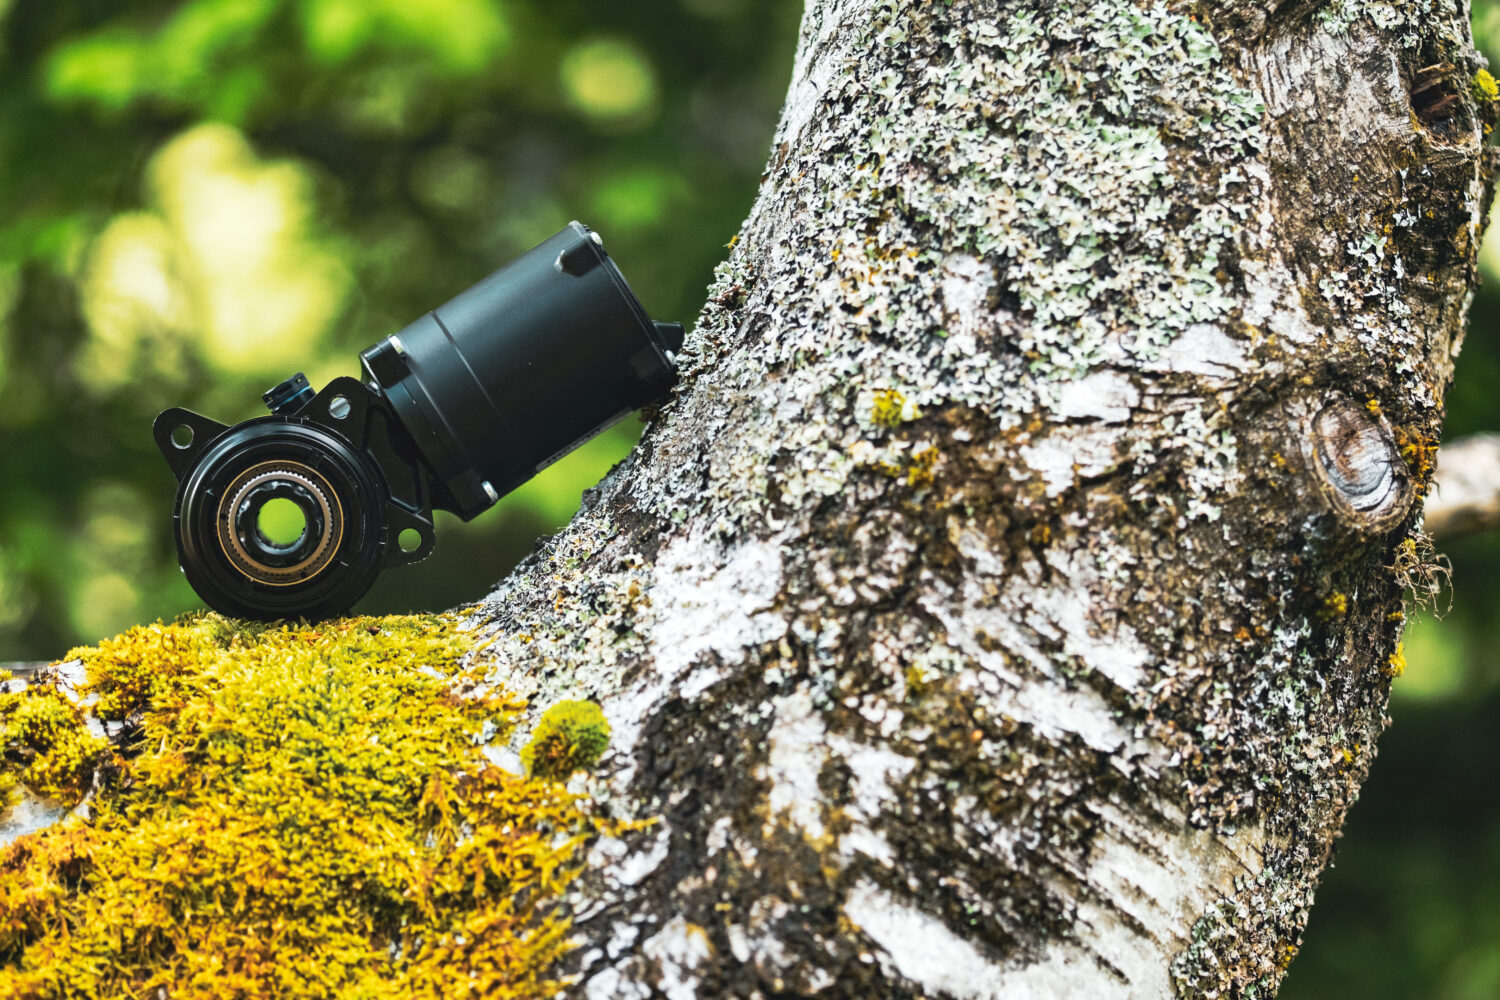
The Maxon range encompasses high-precision electric drive components—including brushed and brushless DC motors, planetary and spur gearheads, high-resolution encoders, and intelligent motion controllers. Engineered by the Switzerland-based Maxon Group, these drive systems are designed for high-power-density, high-efficiency, and low-inertia applications across robotics, medical technology, aerospace, defense, and industrial automation.
While "Maxon" can occasionally refer to commercial vehicle liftgates (Maxon Lift Corp), industrial gas burners (Honeywell MAXON), or 3D graphics software (Maxon Cinema 4D/Maxon One), in mechanical engineering, electromechanics, and motion control, the term overwhelmingly denotes the modular drive technology portfolio developed by Maxon Group. This article provides a comprehensive technical guide to selecting, configuring, and deploying components across the Maxon drive system lineup.
Architecture of the Maxon Product Portfolio
The defining characteristic of the Maxon product range is its modular building-block system (Baukastensystem). Rather than requiring custom, ground-up motor development for every specialized application, engineers can configure matching drive trains by combining standard or customized motor cores with gearheads, feedback systems, and motion controllers.
- MAXON MOTION SYSTEM
- FEEDBACK & SENSORS
- ENX Magnetic / Optical / Ind.
- Hall Sensors & Resolvers
- POWER & ACTUATORS
- DC Motors (RE, DCX, A-max)
- BLDC Motors (EC, ECX, IDX)
- TRANSMISSION
- GP / GPX Planetary Gearheads
- GS Spur Gearheads & Screw Drives
- CONTROL & DRIVES
- ESCON Servo Controllers
- EPOS4 Positioning Controllers
- FEEDBACK & SENSORS
The Core Technological Innovation: Ironless Winding
Central to Maxon's performance advantages is the self-supporting, ironless copper coil system, often designated as the System Maxon. In conventional DC motors, the rotor coils are wound around an iron core, which introduces magnetic cogging (torque ripple), rotor mass inertia, and inductive losses.
By eliminating the iron core from the rotor:
- Zero Cogging Torque: The motor rotates smoothly even at extremely low speeds, making it suited for haptic feedback devices and fine robotic manipulation.
- Low Inertia: The lightweight rotor enables extremely fast acceleration and dynamic response, with mechanical time constants often dropping below 5 milliseconds.
- High Efficiency: Energy losses due to eddy currents and magnetic hysteresis are minimized, yielding motor operating efficiencies frequently exceeding 80% to 90%.
- Linear Characteristics: Speed-torque and voltage-speed relationships remain linear across the operating spectrum, simplifying closed-loop control algorithms.
Core Motor Series in the Maxon Lineup
Maxon categorizes its motor program primarily by commutation method (brushed vs. brushless), construction geometry (cylindrical vs. flat), and manufacturing philosophy (standard catalog vs. configurable online series).
- MAXON MOTOR PORTFOLIO
- BRUSHED DC
- RE Series (Rare-earth magnets, high power)
- DCX Series (Configurable, high density)
- A-max Series (Alnico magnets, cost-efficient)
- BRUSHLESS DC
- EC Series (Standard slotless BLDC)
- ECX Series (Configurable, high speed)
- EC-max Series (Slotted, high torque/cost)
- EC flat Series (Multipole, compact)
- IDX Series (Integrated IP65 drives)
- BRUSHED DC
1. Brushed DC Motors
Brushed DC motors feature simple driving dynamics requiring only a DC voltage source to operate, making them straightforward to integrate.
- Maxon RE Series: Utilizing high-grade rare-earth magnets (NdFeB), the RE series delivers the highest power density among brushed motors. They are widely specified in demanding applications such as surgical tools, space exploration instruments, and precision optical positioning.
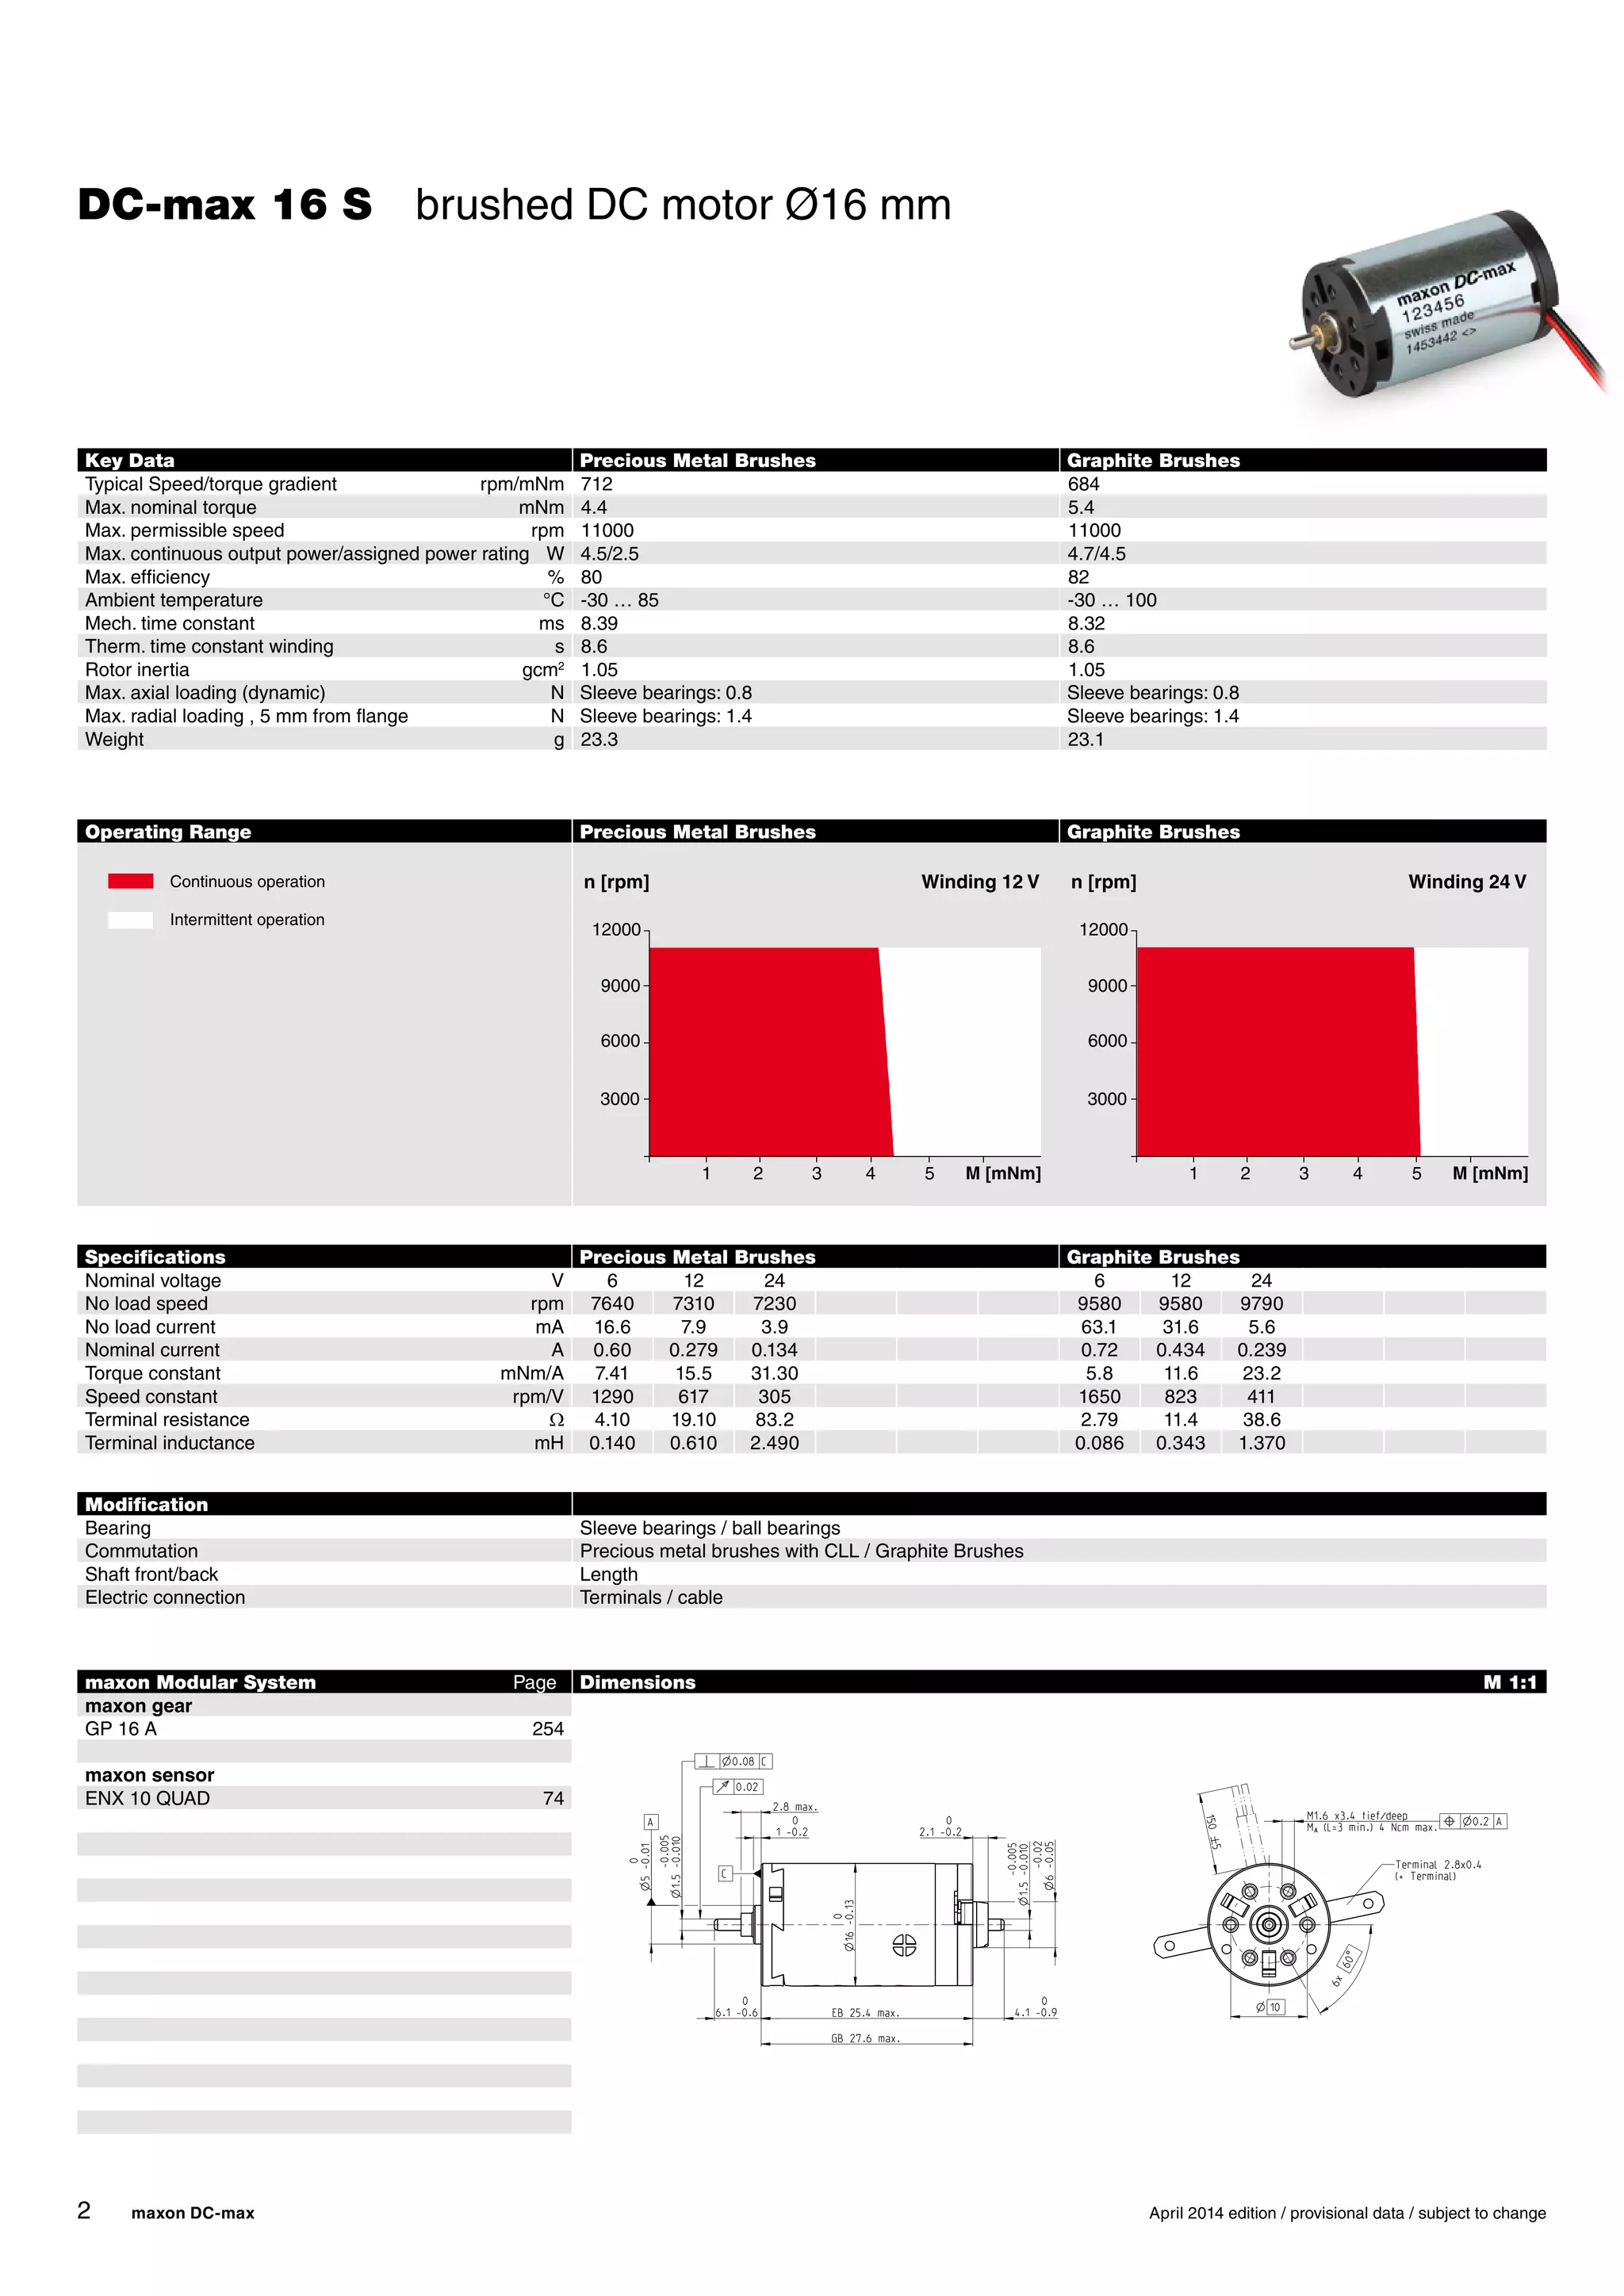
- Maxon DCX Series: The DCX line represents Maxon's high-performance, digitally configurable motor platform. Engineers can select motor length, shaft diameter, bearing type (sleeve vs. ball), brush material (precious metal vs. graphite), and terminal options online, with short delivery windows.
- Maxon A-max Series: Utilizing Alnico magnets and an automated assembly process, the A-max range provides a cost-optimized alternative for applications where extreme power density is secondary to production economics.
Commutation Selection: Precious Metal vs. Graphite Brushes
- Precious Metal Brushes: Offer low contact resistance and low starting voltage. Ideal for continuous, low-current operations, low-voltage battery power, and noise-sensitive instrument applications.
- Graphite Brushes: Built for heavy duty cycles, high current surges, and start-stop operation. They exhibit superior wear characteristics under high power loads.
2. Brushless DC Motors (BLDC / EC Motors)
For continuous-duty applications, high speeds, or harsh environments where mechanical brushes would wear out, Maxon produces Electronically Commutated (EC) motors.
- Maxon EC Series: Standard slotless BLDC motors offering high speeds (up to 50,000 RPM or higher) and long operational lifespans dictated primarily by ball bearing wear.
- Maxon ECX Series: High-speed, configurable brushless motors. The ECX range includes specialized sterilizable versions designed to withstand over 2,000 autoclave cycles, making them standard equipment in medical handpieces and surgical power tools.
- Maxon EC-max Series: Features slotted iron-core geometries that offer high torque per unit volume at an economical price point, serving industrial robotics and automated guided vehicles (AGVs).
- Maxon EC Flat Series: Designed as multipole pancake motors, the flat series provides high torque in short axial lengths. These are suitable for exoskeleton joints, wheel drives, and robotics where axial space is restricted.
- Maxon IDX Series: Industrial-grade brushless motors featuring integrated positioning controllers and heavy-duty housing rated up to IP65. IDX units support direct fieldbus connection (EtherCAT, CANopen) for factory automation.
Transmission Components: Gearheads and Screw Drives
Because high-speed electric motors produce relatively low raw torque, Maxon provides complementary mechanical gearheads to reduce speed and multiply output torque.
- MAXON GEARHEAD TYPES
- PLANETARY GEARHEADS (GP/GPX)
- High torque transmission
- Coaxial input/output
- Scalable stage count
- Ceramic component options
- SPUR GEARHEADS (GS)
- High efficiency at low load
- Offset output shaft
- Low acoustic noise
- Low radial backlash
- PLANETARY GEARHEADS (GP/GPX)
Planetary Gearheads (GP and GPX Series)
Planetary gearheads distribute loads across multiple planet gears, providing high torque capacity within a small diameter.
- High-Torque (HP) and Heavy-Duty (HD) Options: Standard planetary gearheads use steel components, while heavy-duty variants utilize ceramic components (zirconia/silicon nitride) on pinions and shafts to reduce mechanical wear and extend service life under high radial loads.
- Configurable GPX Series: Designed to mate seamlessly with DCX and ECX motor lines, allowing fully customized drive stacks built to precise length and gear ratio requirements.
Spur Gearheads (GS Series)
Spur gearheads offer low-noise, high-efficiency transmission for low-torque, continuous applications. Because the output shaft is offset from the motor center line, they fit specific physical packaging requirements where coaxial planetary layouts cannot.
Lead Screws and Ball Screws (GP S / GPX S)
Integrated linear actuators convert rotational motion directly into high-thrust linear positioning. Maxon integrates precision rolled lead screws or high-efficiency ball screws into the gearhead housing, eliminating internal axial couplings and simplifying linear axis design.
Feedback and Control Infrastructure
A complete drive system requires sensors for closed-loop motion control and power electronics to convert command signals into motor phase currents.
- SYSTEM HARDWARE ARCHITECTURE
- Higher-Level Controller (PLC / IPC)
- EtherCAT / CANopen connection to Maxon EPOS4 / ESCON (Power Inverter)
- Maxon EPOS4 / ESCON (Power Inverter)
- Drives Drive Electronics
- Phase Currents to Maxon Motor (RE/ECX/DCX)
- Maxon Motor (RE/ECX/DCX)
- Shaft Position Feedback to Maxon ENX Encoder
- Higher-Level Controller (PLC / IPC)
Encoders (ENX Series)
Maxon offers a wide array of optical, magnetic, and inductive feedback encoders:
- Magnetic Encoders (e.g., ENX MAG/EASY): Highly compact and resistant to dust, oil, and physical shock.
- Optical Encoders (e.g., ENX HEDL/OPTICAL): Provide high line counts (up to thousands of counts per revolution) for precise velocity and position control.
- Inductive Encoders (e.g., ENX RIO): Insensitive to strong magnetic fields generated by nearby braking systems or high-power electronics, offering reliable resolution in compact form factors.
Motion and Servo Controllers
ESCON Controllers
ESCON units are compact, 4-quadrant PWM servo controllers designed for speed and current (torque) regulation of brushed and BLDC motors. They rely on analog/digital input signals rather than complex bus protocols, providing fast setup for single-axis speed regulation.
EPOS4 Controllers
EPOS4 (Easy Positioning System) represents Maxon's modular positioning controller line. These devices support advanced control modes (Profile Position, Profile Velocity, Cyclic Synchronous Position via CANopen and EtherCAT) and feature integrated thermal monitoring, fast current loops (up to 25 kHz), and dual-loop feedback processing to eliminate mechanical play in high-precision robotics.
Comprehensive Specifications Comparison Matrix
The following reference table compares the core performance parameters across major series within the Maxon range.
| Series Family | Motor Type | Commutation / Design | Max Speed (RPM) | Max Continuous Power Range | Primary Strengths | Typical Target Applications |
|---|---|---|---|---|---|---|
| Maxon RE | Brushed DC | Precious Metal / Graphite | 8,000 – 18,000 | 0.5 W – 250 W | Ironless rotor, highest efficiency, peak power density | Surgical systems, optics, space instruments |
| Maxon DCX | Brushed DC | Configurable Precious/Graphite | 5,000 – 15,000 | 1 W – 120 W | Fully online configurable, high power/volume ratio | Prototyping, custom robotics, aerospace actuators |
| Maxon A-max | Brushed DC | Alnico / Precious Metal | 8,000 – 12,000 | 0.5 W – 11 W | Cost-effective ironless core, robust design | Consumer devices, low-cost automation |
| Maxon EC | Brushless | Slotless Electronic | 10,000 – 50,000 | 5 W – 400 W | Long operational life, high speed, zero maintenance | Medical pumps, lab automation, high-duty fans |
| Maxon ECX | Brushless | High-Speed / Sterilizable | 20,000 – 120,000+ | 10 W – 200 W | Extreme RPM capacity, autoclavable configurations | Surgical handpieces, dental drills, dynamic grippers |
| Maxon EC flat | Brushless | External Rotor / Multipole | 4,000 – 12,000 | 0.2 W – 90 W | Flat short axial design, high passive output torque | Exoskeletons, robotic joint drives, wheel hub motors |
| Maxon IDX | Brushless | Slotted / Integrated EPOS4 | 3,000 – 6,000 | 200 W – 750 W | Integrated controller, IP65 protection, industrial fieldbus | AGVs, factory automation, logistics conveyors |
Technical Selection and Sizing Process
To select the correct drive solution from the Maxon range, engineers use a structured sizing process based on load characteristics and thermal operating limits.
- Determine Load Profile (Torque, Speed, Duty Cycle)
- Select Gearhead (Ratio, Efficiency, Max Radial/Axial Loads)
- Calculate Motor Parameters (Reflected Torque, Required Speed)
- Verify Thermal Limits (RMS Torque vs Continuous Torque Limit)
- Select Feedback & Controller (Encoder Resolution, EPOS4 / ESCON)
Step 1: Calculate Load Dynamics
Determine the required speed ($\omega_L$) and torque ($T_L$) profiles over time, accounting for peak acceleration phases and steady-state friction:
$$T_{\text{accel}} = J_{\text{total}} \cdot \alpha + T_{\text{friction}}$$
Where $J_{\text{total}}$ includes the load inertia and gearhead inertia, and $\alpha$ is angular acceleration.
Step 2: Determine Gearhead Reduction Ratio ($k_g$)
Select a gearhead ratio that transforms the working load speed into the optimal operational speed range of the motor (typically between 2,000 and 8,000 RPM for brushed/standard BLDC motors):
$$\omega_{\text{motor}} = \omega_L \cdot k_g$$
Calculate the required motor torque ($T_{\text{motor}}$), adjusting for gearhead mechanical efficiency ($\eta_g$):
$$T_{\text{motor}} = \frac{T_L}{k_g \cdot \eta_g}$$
Step 3: Check Thermal Limits via RMS Torque
Because electric motors generate internal heat ($I^2 R$ losses), continuous operation must stay below the motor's nominal torque rating ($T_{\text{nom}}$). Calculate the Root Mean Square (RMS) torque across the complete duty cycle time ($t_{\text{total}}$):
$$T_{\text{RMS}} = \sqrt{\frac{\int_{0}^{t_{\text{total}}} T(t)^2 , dt}{t_{\text{total}}}}$$
To avoid overheating, verify that:
$$T_{\text{RMS}} \le T_{\text{nom}}$$
If $T_{\text{RMS}}$ exceeds $T_{\text{nom}}$, select a larger motor frame size or implement forced air/liquid cooling.
Application Implementations
| FIELD | PRIMARY MAXON SOLUTION | CRITICAL BENEFIT |
|---|---|---|
| Space & Aerospace | RE 25 / GP 22 HD / ENX High-Temp Ceramic | Zero vacuum outgassing, wide temp |
| Surgical Tools | ECX Speed 16 / 19 Sterilizable Gearhead | Autoclavable, high power-to-weight |
| Robotics / AGVs | EC flat / IDX integrated drives EPOS4 EtherCAT | Compact axial profile, IP65 |
Space and Extreme Environments
Maxon motors are frequently selected for space missions, including the NASA Mars rovers (Sojourner, Spirit, Opportunity, Curiosity, and Perseverance) and the Ingenuity Mars Helicopter.
Space-rated variants feature specialized lubricants capable of operating in high vacuum environments, custom ceramic shafts, modified winding insulation, and custom thermal stress-relief designs to withstand vibration during launch and ambient temperatures ranging from -120°C to +125°C.
Medical and Surgical Robotics
In surgical robotics (e.g., haptic master-slave surgical arms and arthroscopic handpieces), zero cogging torque and high power density are essential. The ECX Sterilizable range features hermetically sealed motor housings and potted windings that prevent steam ingress during high-pressure autoclave sterilizations (134°C at 2.3 bar).
Autonomous Mobile Robots (AMRs) and Industrial Automation
For battery-operated warehouse AMRs and industrial joint modules, power draw and physical envelope drive component selection. The EC flat series combined with EPOS4 controllers allows designers to integrate drive hardware directly inside wheel structures or robotic arm joints, maximizing payload volume and battery operating hours.
System Integration, Troubleshooting, and Best Practices
1. Thermal Management and Heat Dissipation
Although ironless motors achieve high efficiency, their compact dimensions mean thermal mass is relatively low. Thermal resistance values—junction-to-housing ($R_{th1}$) and housing-to-ambient ($R_{th2}$)—must be reviewed carefully.
- Heatsinking: Mounting the motor flange to a metal structural plate significantly reduces $R_{th2}$, allowing higher continuous current operation.
- Winding Temperature Monitoring: Utilize integrated NTC thermistors or PT1000 sensors available on ECX/EPOS4 platforms to trigger software-side current derating before winding insulation degrades (typically at 125°C or 155°C).
2. Electromagnetic Interference (EMI) Mitigation
High-speed PWM switching in BLDC motor drives (e.g., 20 kHz to 100 kHz switching loops) can introduce EMI into low-level feedback lines.
- Use twisted-pair, double-shielded cabling for encoder lines and motor phase leads.
- Keep power lines separated from logic and feedback lines by at least 50 mm where parallel routing cannot be avoided.
- Ensure full ground-plane continuity across motor housings, gearheads, and drive enclosures.
3. Gearhead Backlash and Radial Load Protection
Standard planetary gearheads exhibit mechanical backlash (typically between 0.5° and 2.0°).
- In high-precision positioning axes, dual-loop control architecture (using a motor shaft encoder combined with an absolute load-side encoder) prevents mechanical play from inducing control loop oscillation.
- Avoid applying excessive radial forces directly to output shafts. Use external pillow blocks or select heavy-duty ball-bearing option gearheads if high belt tension or cantilevered pinion loads are present.
Frequently Asked Questions
What is the difference between Maxon RE and Maxon EC motors?
Maxon RE motors are brushed DC motors utilizing rare-earth magnets and ironless rotors, requiring only a simple DC voltage to operate. Maxon EC motors are brushless DC motors (electronically commutated) that require an electronic drive controller (such as an ESCON or EPOS4) to handle phase commutation. EC motors offer longer operational lifespans and higher top speeds because they lack mechanical brushes.
How do ironless rotors improve motor performance in the Maxon range?
Ironless rotors eliminate magnetic cogging, providing smooth movement at low speeds and low mechanical inertia. This design enables fast acceleration, minimizes energy losses from eddy currents, and yields linear torque-speed performance curves.
Can components from different Maxon product lines be combined?
Yes. The modular design principle allows standard or custom motors (DCX, RE, ECX) to pair with compatible gearheads (GP/GPX), encoders (ENX), and controllers (EPOS4/ESCON). Compatibility can be validated through the Maxon online configuration tool.
What options are available for harsh or sterile environments?
Maxon produces specialized configurations, including the ECX sterilizable series for steam autoclaves, IP65-rated housing options (such as the IDX series) for dust and splash resistance, and space-grade modifications using low-outgassing lubricants and radiation-resistant materials.
Which motion controller line should be chosen: ESCON or EPOS4?
Select ESCON for simple speed or torque control using analog setpoints or PWM signals without complex fieldbus networking. Choose EPOS4 for multi-axis positioning applications requiring bus interfaces (EtherCAT or CANopen), dual-loop feedback, interpolated motion profiles, or complex motion control sequences.
Next Steps and Recommendations
- Calculate Operational Loads: Map out the torque, velocity, duty cycle, and inertia constraints of your mechanical axis before selecting hardware.
- Utilize Configuration Tools: Use the online Maxon Selection Program (MSP) and product configurator tools to evaluate motor curves, continuous operating boundaries, and gearhead combinations.
- Verify Thermal Requirements: Calculate the $T_{\text{RMS}}$ load to ensure operating temperatures remain within limits, and evaluate mounting surface heat dissipation.
- Order Evaluation Kits: Validate system dynamics in physical prototypes using EPOS4 controller development boards before finalizing printed circuit board designs or fieldbus integration schedules.